
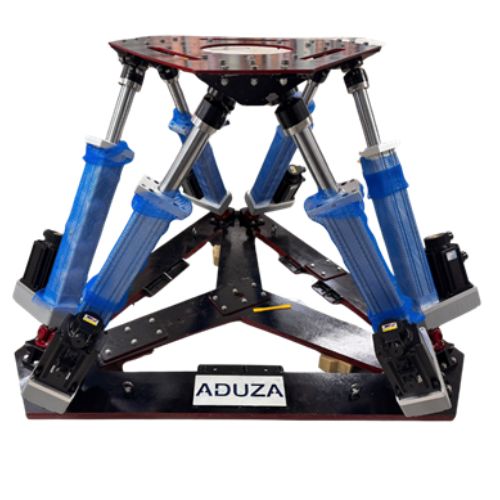
The ADUZA 6UPS (Gough–Stewart Platform) is a customised parallel robotic system developed for the Ocean Engineering Department at IIT Madras and designed specifically for advanced wave-simulation.
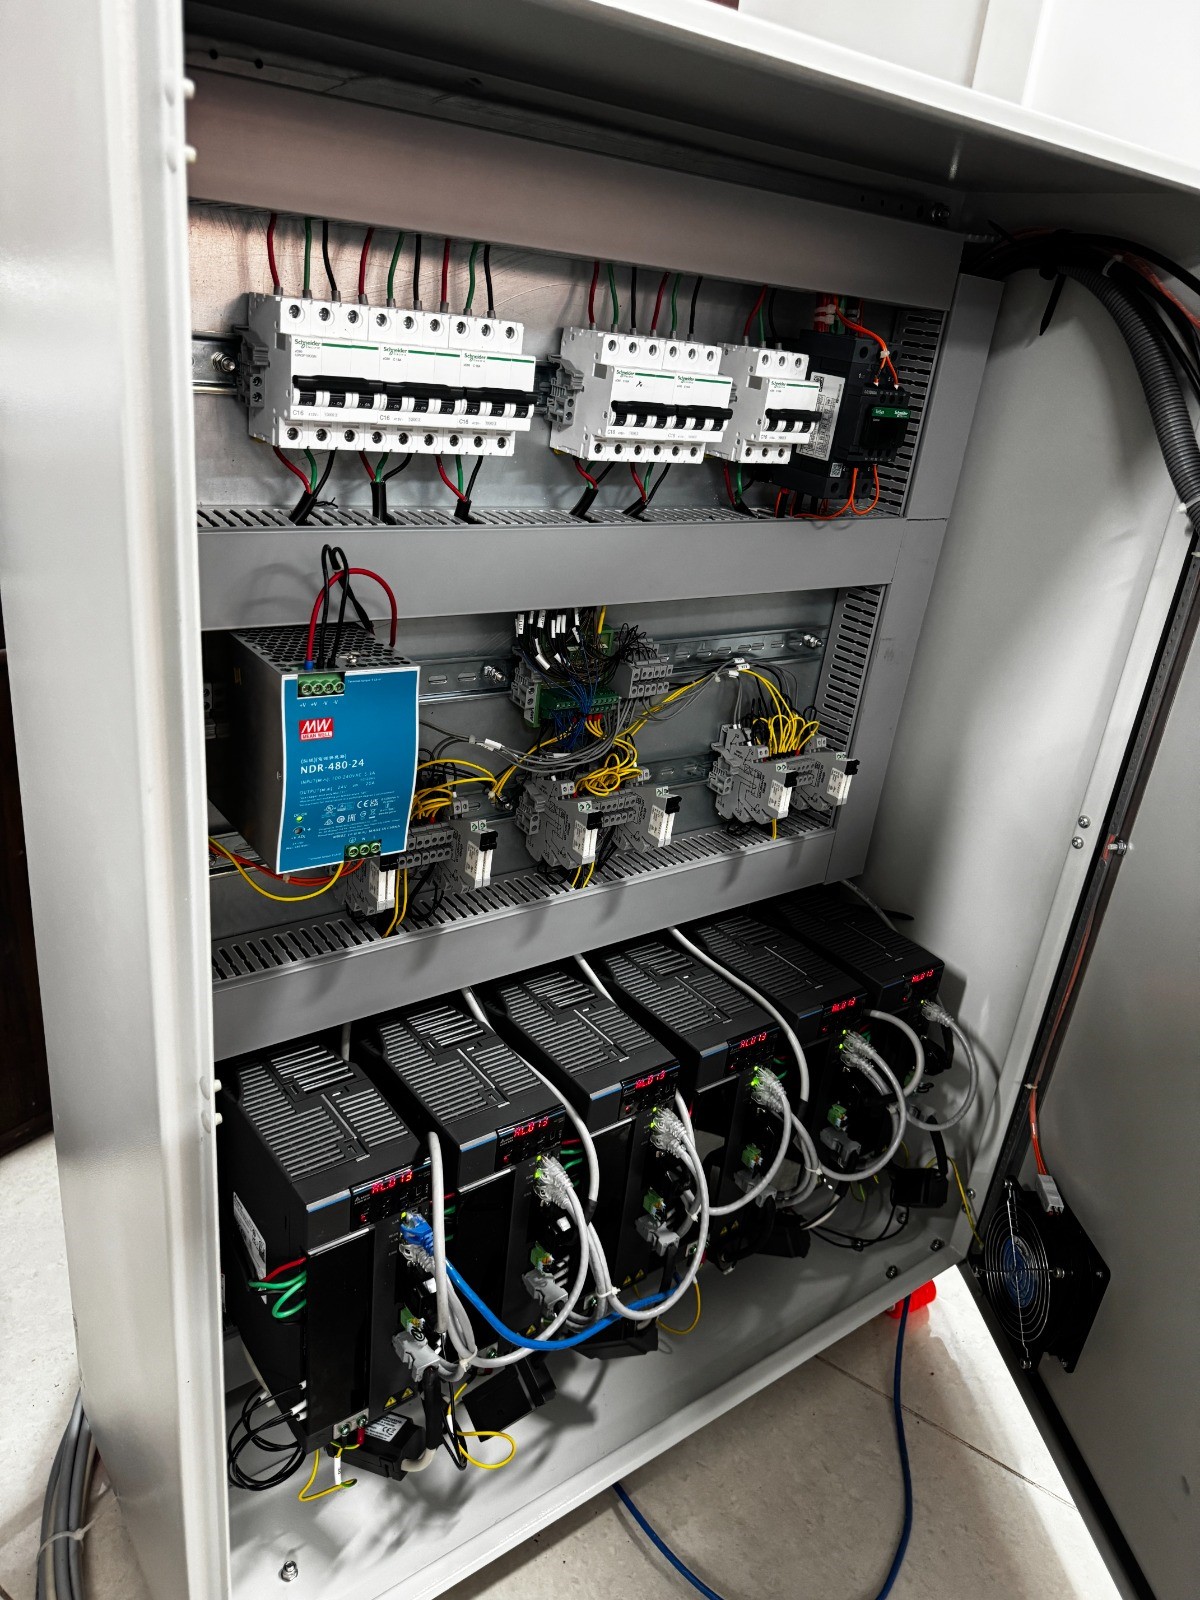
This high-precision platform is built with industrial-grade controllers and a fully integrated EtherCAT-based control architecture, ensuring real-time performance, synchronisation, and reliability in demanding research environments.
KEY FEATURES
| Configuration | 6UPS parallel mechanism (Universal–Prismatic–Spherical joints) |
| Workspace | 400 mm × 400 mm × 400 mm |
| Orientation Range |
|
| Payload Capacity | Up to 500 kg |
| Control System | Industrial controllers with EtherCAT communication |
| Structure Type | Universal–Prismatic–Spherical parallel configuration |
Capabilities
The platform is engineered to accurately replicate complex wave motions and multi-axis dynamic environments. With six synchronised actuators, it delivers precise control over both translational and rotational degrees of freedom, making it ideal for:
- Wave simulation studies
- Marine structure testing
- Motion replication systems
- Advanced robotics research
Engineering Highlights
- High structural rigidity for heavy payload handling
- Smooth and precise multi-axis motion control
- Scalable and customizable architecture
- Robust design suitable for continuous industrial and research use
Working Demonstration
A live demonstration of the ADUZA 6UPS platform showcases its ability to perform synchronised six-degree-of-freedom motion with high accuracy and stability.
Get in Touch
Want to get in touch? We’d love to hear from you. Here’s how you can reach us…
Contact Us