
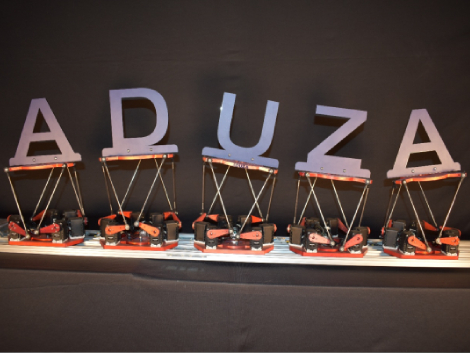
This system demonstrates the synchronous motion of a parallel robotic platform built using five ADUZA RED robots. The setup showcases advanced multi-robot coordination, where all units operate in perfect synchronisation to generate complex wave-like motions. Designed for research and simulation, this platform highlights the capabilities of distributed robotic systems to function as a unified motion system.
System Overview
- Robotic Units: 5 × ADUZA RED robots
- Architecture: Distributed parallel platform
- Control: Synchronised multi-robot coordination
- Application Focus: Wave motion simulation and coordinated actuation
Key Capabilities
- Independent Operation: Each robot can perform precise motion individually
- Synchronous Motion: All five robots operate in coordination for unified movement
- Wave Simulation: Ability to generate complex wave-like patterns
- Dynamic Motion Control: Supports both structured and random motion profiles
Demonstrated Motion Types
The system showcases a wide range of motion patterns, including:
- Individual robot motion
- Random synchronized motion
- Planar see-saw motion
- Planar sine wave motion
Engineering Highlights
- High-precision synchronisation across multiple robotic units
- Scalable architecture for larger multi-robot systems
- Smooth and coordinated motion generation
- Suitable for simulation, research, and advanced robotics applications
Working Demonstration
Get in Touch
Want to get in touch? We’d love to hear from you. Here’s how you can reach us…
Contact Us