
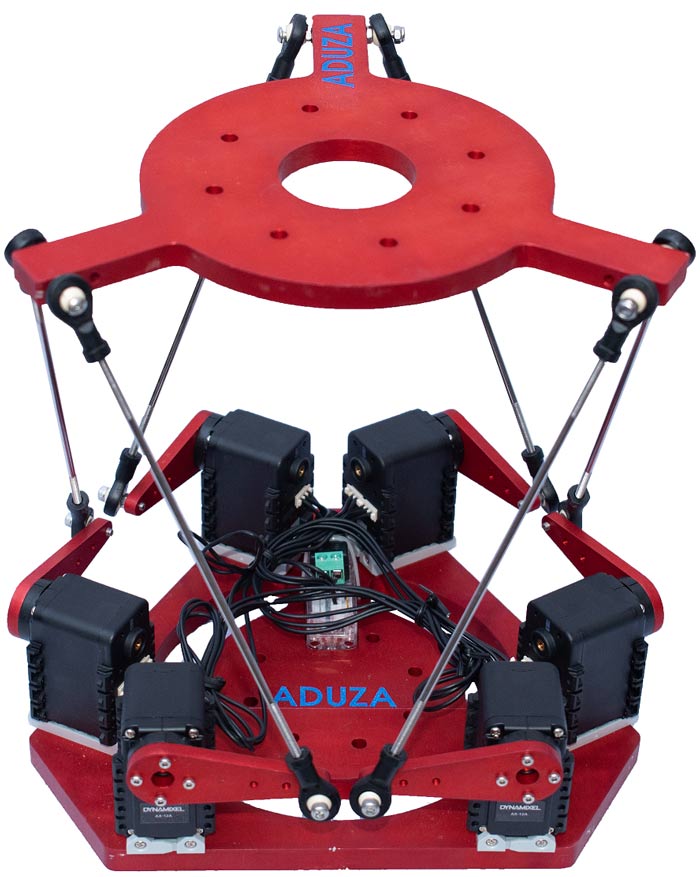
This is an inexpensive 3D Printed 6-RSS parallel platform built specially to accommodate institutes with low budgets and any hobbyist who intends to introduce this highly capable 6-DoF parallel platform to their projects. It comes with a fully-featured GUI as with our robust INVERTA-8 platform. Even the programming interface is like our HEXA-4 or INVERTA-8 robots.
 Technical Specifications |
 Information Brochure |
 Demonstration of capabilities of 3D Printed 6-DoF parallel robot. |
FEATURES
- Modular design, with red anodized aluminum top and bottom plates, and stainless steel links.
- Comes with a base stand with provisions to be mounted on any suitable location.
- Top platform has suitable provisions for mounting sensors, grippers, etc.
- Improved design of the top platform provides makes it light weight and more agile.
- Individual joint position plots, joint angles, homogeneous transformation matrix, and end-effector pose are shown live during motion using GUI.
- User programmable PID gains, contactless absolute encoder, and position/velocity control of actuators.
- Full customizations in terms of hardware and software may be provided on request.
- Readily available spares and prompt support.
- Designed and developed proudly in India.
Brief Technical Specifications
| Controlled Axes | 6 |
| Weight (kg) | 2.7 |
| Pose repeatability (mm) | ± 0.2 |
| Maximum Payload (kg) | 0.5 |
| Maximum Displacement (mm) | 80 x 80 x 40 |
| Maximum Angular Displacement (degrees) | 5 x 25 x 30 |
| Cubical Workspace (mm x mm x mm) | 160 x 160 x 80 |
| Joint Angle Precision | 0.08 |
Brief Software Specifications
| Direct control | GUI and Joystick (not Included) |
| API for external control | Python |
| API for external control (optional) | MATLAB, LabView, Java, C/C++, Visual Basic, Eclipse, ROS |
| GUI Trajectories Supported | Cycloid, Quintic, Cubic, Cosine |
| Planned Motions | Helical, Spiral, Lissajous, Vertical SHM, Elliptical, and Precession |
APPLICATIONS
- As a laboratory apparatus for demonstrating parallel robots.
- Designed for a variety of UG/PG Labs including Robotics and Control Labs.
- Positioners: e.g. for cameras, solar plates, mirrors, surgical instruments, etc.
- Low-frequency vibration compensators or dynamic balancing (needs appropriate sensors)
- Motion platform: e.g. simulators, gaming stations, medical applications, test workbench, etc
Working Demonstration
Get in Touch
Want to get in touch? We’d love to hear from you. Here’s how you can reach us…
Contact Us